42.195 km Without a Single Battery Change... KAIST Robot Completes Marathon
- Input
- 2026-09-24 00:00:00
- Updated
- 2026-09-24 00:00:00
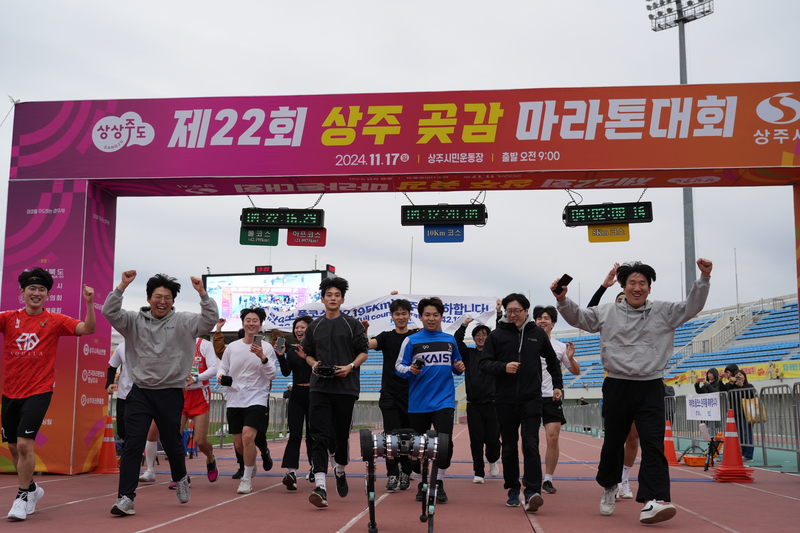
[Financial News] A quadruped robot ran the full 42.195-kilometer marathon without changing its battery, a distance that is difficult even for humans to complete. Researchers at KAIST developed this world-first achievement into design principles for long-distance operation, published their findings in Nature, and are moving to commercialize robots for use in real industrial settings.
KAIST announced on the 24th that the long-distance locomotion technology and actual marathon completion results of RAIBO2, a quadruped robot developed by a research team led by Jemin Hwangbo of the Department of Mechanical Engineering, were published in the flagship journal Nature on the 23rd local time. This marks the first time research conducted in Korea has been published in the main journal Nature. Robot research being published in Nature is also extremely rare worldwide, and the achievement is being recognized as evidence of both the technological capabilities and academic standing of Korea's robotics research.
According to the research team, RAIBO2 completed the full 42.195-kilometer course at the Sangju Dried Persimmon Marathon in November 2024 in 4 hours, 19 minutes, and 52 seconds without charging or changing its battery. It is the first known case in the world of a quadruped robot completing the full course of an actual marathon.
The team approached long-distance locomotion not as a problem involving the performance of individual components such as batteries or motors, but as a system-wide robotics problem in which the mechanical structure, electrical system, and walking control are closely interconnected. The researchers systematically analyzed energy losses throughout the robot and integrated the design of its mechanics, electrical systems, actuation, and control systems to reduce energy consumption while maintaining high locomotion performance. This led to concrete design principles for the factors that must be considered together to enable a quadruped robot to move stably for extended periods.
In particular, the researchers recorded the robot's internal voltage, current, temperature, and battery status in real time throughout the marathon, synchronizing the data with location, speed, and altitude information measured by GPS. RAIBO2 was registered as an official participant, leaving official split records, while the researchers ran alongside the robot and recorded the entire run—from the start to the finish line—which lasted more than four hours.
The data provided scientific evidence of how the robot was able to complete the marathon and how its performance was maintained in a real-world environment. The team developed the result beyond a single impressive demonstration into a research achievement based on system design principles and measured data that can be analyzed and independently validated.
The research team's next task is to transfer the performance demonstrated by a single research robot into a product that can be used repeatedly in industrial settings. RAION ROBOTICS, a KAIST faculty-founded startup launched from Professor Hwangbo's laboratory, is responsible for connecting the research achievement to real-world products.
Drawing on its system design capabilities, RAION ROBOTICS is currently developing commercialization and mass-production technologies for quadruped robots capable of long-term operation in real-world settings, moving beyond research prototypes.
Jemin Hwangbo said, "This study goes beyond showing how far a quadruped robot can run. Using actual marathon data, it demonstrated how the entire robot should be designed to achieve both high locomotion performance and energy efficiency. We will turn the world-class performance achieved in the laboratory into products that anyone can use reliably in industrial settings."
[email protected] Yeon Ji-an Reporter